1
A sensor used in an industry to sense extra heat.
Show SolutionHide Solution↓
Temperature sensor
ICSE Class 9 Robotics & AI · Solutions for Class 9 KIPS ICSE Robotics & Artificial Intelligence · 41 solved questions
A sensor used in an industry to sense extra heat.
Temperature sensor
A sensor that can detect the presence of an object.
Infrared (IR) sensor
A sensor, which is like human skin, that detects the moisture level in the air.
Humidity sensor (Hygrometer)
Observe the robots and identify their given components.

| Component | Robot 1 | Robot 2 |
|---|---|---|
| Sensor | ||
| Actuators |
| Component | Robot 1 | Robot 2 |
|---|---|---|
| Sensor | Camera sensor (visual sensor) | Pressure sensor |
| Actuators | Electric actuator | Hydraulic Actuators |
Write names of any five microcontrollers that are commonly used in robot designing.
Some commonly used microcontrollers in robot designing are:
Explore the internet or look at the various devices installed at your home or school and find out the data transfer range of the following wireless devices:
Observe the following humanoid robot and identify its various components. Write the components under appropriate headings in the space provided for answer.
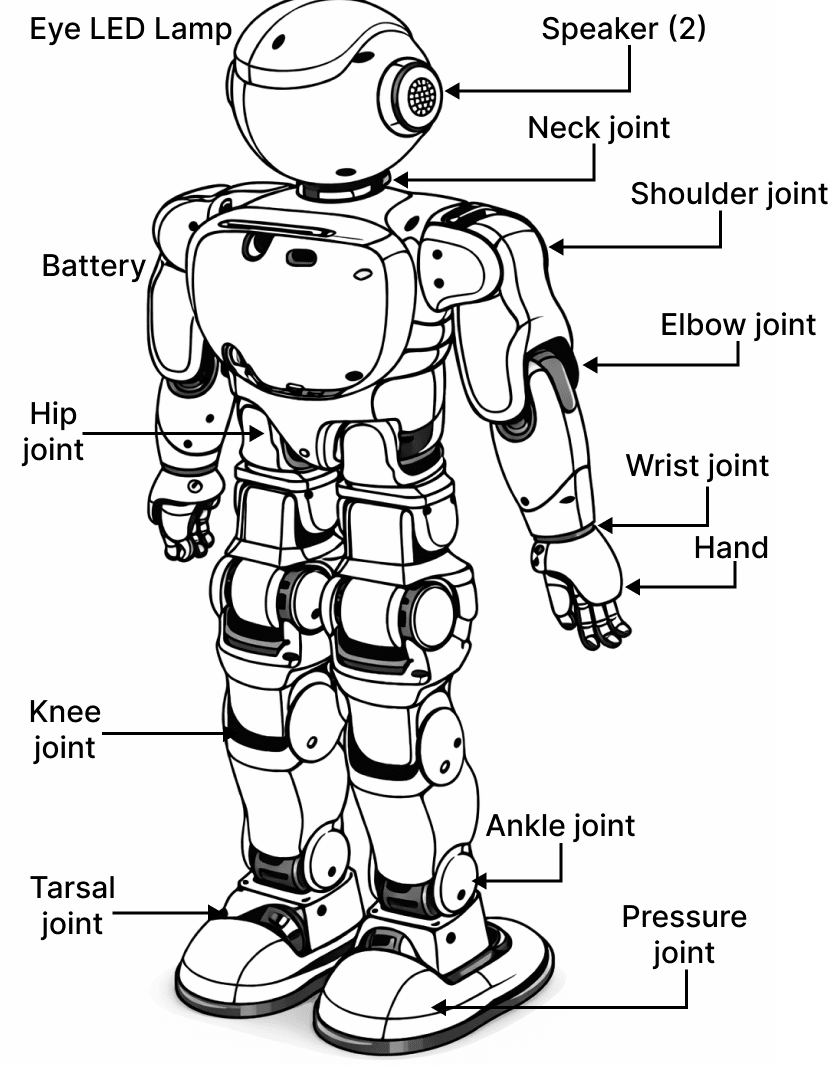
Sensors
Power Sources
Manipulators
Sensors:
Power Sources:
Manipulators:
Observe the workflow of a mobile robot, which is used in a warehouse to transport packages and create similar workflows for different robots in the industry.
Step 1: Request: Receive transport request from the operator or warehouse manager.
Step 2: Navigation: Navigate in warehouse by using sensors and cameras. The sensor and camera input goes to the controller. It generates signals for the actuators to avoid obstacles and find a suitable path.
Step 3: Pickup the package: After reaching the destination, the robot uses a gripper to pick up the package. The package may be located at a shelf or conveyor.
Step 4: Send package: After picking up the package, the robot sends the package to the desired location, which may be an area within the warehouse, loading dock, or shipping area. For this, again, the robot navigates with the help of sensors, actuators and manipulators, and all the control signals are generated by the controller of the robot.
Step 5: Deliver package: The robot delivers the package to the designated location by releasing grippers or any other mechanism.
Step 6: Return: The robot goes back to its starting location or charging station and waits for the next request.
Workflow of Yamaha YK400XR Industrial Robot:
Step 1: Task Request: The Yamaha YK400XR robot receives a task request from the industrial control system for welding or material handling.
Step 2: Positioning: The robot positions its arm at the required work location using sensors. Sensor input is sent to the controller, which generates signals for actuators to move the joints accurately.
Step 3: Perform Operation: After reaching the correct position, the robot performs the assigned task such as welding, pick-and-place, or assembly using the appropriate end-effector.
Step 4: Monitoring: During the operation, sensors continuously monitor position and accuracy. The controller adjusts actuator movement if required.
Step 5: Task Completion: Once the task is completed, the robot stops the operation and releases the component.
Step 6: Reset / Standby: The robot returns to its home position and waits for the next task request.
Sensors are used to measure environmental variables.
True
Reason — Sensors are the devices that are used to detect changes in the environment based on some features, like temperature, pressure, light, sound and distance.
A light sensor detects the presence of an object.
True
Reason — A light sensor emits light and observe its reflection to detect the obstacle or follow a particular path.
The temperature sensors are used to sense humidity.
False
Reason — Temperature sensors are used to sense temperature, while humidity is sensed using humidity sensors.
Actuators are used to generate a signal or force.
True
Reason — Actuators are the devices that are used to convert electrical signals into physical movements. Their movements can be used to control the motion of the robot, such as its arms, legs, wheels, or grippers. That means, the actuators are used to perform an action.
In piezoelectric actuators, pressurised fluid is used to generate motion.
False
Reason — Piezoelectric actuators move objects using a piezoelectric crystal, while pressurised fluid is used by hydraulic actuators to produce motion.
Roomba is an example of a battery.
False
Reason — Roomba is not a battery, it is a robotic vacuum cleaner.
Manipulators are made up of links and joints.
True
Reason — Manipulators are combinations of links and joints. Links are the main sections that have the mechanism and joints are the connections between two links.
Sensing is a function of the mechanical block of a robot.
False
Reason — Sensing is performed by the sensors in the electronic block of a robot which detects environmental changes and provides input to the robot. The mechanical block of a robot provides a mechanism for movement and interaction of the robot with its environment.
Decision making in robot is done by the computational block of the robot.
True
Reason — The computational block is the most important block and considered as the brain of the robot. This block processes the information and generates the commands for the electronic and mechanical blocks. Hence, decision making in a robot is done by the computational block.
Underwater robots require a propulsion system to move in the water.
True
Reason — Underwater robots should have a propulsion system to help them move in water. It can be achieved by using thrusters, propellers or other propulsion systems.
Which of the following is/are the robotic component(s)?
All of these
Reason — A robot system consists of sensors (to sense environmental changes), a controller (to process information and make decisions), and actuators (to convert signals into physical action). Hence, all the given options are robotic components.
Which out of the following is not a sensor?
Battery
Reason — Infrared, pressure, and temperature are sensors used to detect environmental conditions, whereas a battery is a power source used to supply energy to the robot and does not perform sensing.
Actuators can be considered as:
Human muscles
Reason — Actuators are devices that are used to make the robots perform an action, like move or pick up something. The operation of actuators can be understood by comparing them with our own hands and legs. Therefore, actuators can be considered as the muscles that assist in the movement of the robots.
Piezoelectric actuators are suitable for:
Small scale precise motion
Reason — Piezoelectric actuators move objects by using a piezoelectric crystal. These are used for small-scale applications where accurate solutions are required. These are used for ultra-precise positioning systems.
Controllers execute tasks on the basis of their ............... .
Programming
Reason — In robots, a controller is the device that controls all their actions. It means that a controller helps the robots decide the output according to the input. They perform the tasks according to their programming. The controller processes the input information given by the sensors and helps the robot to take the appropriate action.
The ............... are the tools that are attached to the end of a manipulator.
End-effectors
Reason — The End-effectors are the tools that are attached to the end of a manipulator.
For underwater robots, the suitable design material would be:
All of these
Reason — Underwater robots should be made up of a material which is able to handle environmental factors in the ocean. Commonly, they are made up of titanium, stainless steel and polymers.
The ............... provides body structure to the humanoid robot and helps it to move and balance.
Torso
Reason — The torso of a humanoid robot consists of a chest, waist and back, which are made up of various sensors, actuators and supporting structure. The torso provides body structure to the robot and helps it to move and balance.
An aerial robot should contain ............... .
A payload that does not affect its flying
Reason — Payload means the extra load that a robot can carry. The robots are designed to carry some equipment or sensors for easy and fast transportation. The design and weight of payload should not affect the flight performance of the robot.
Which of the following is not an example of a mobile robot?
Talos
Reason — Talos is a humanoid robot, whereas Roomba, Spot, and Kiva are examples of mobile robots.
How do the ultrasonic and infrared sensors work?
Ultrasonic sensors — These sensors are used to detect an object or obstacle. These are based on sound waves. It means that the presence of an object is detected through transmission and reflection of sound waves. These sensors help robots to navigate from one location to another.
Infrared sensors — IR sensors use infrared rays that help in detecting the presence of an object. These sensors emit infrared light and observe its reflection to detect the obstacle or follow a particular path.
What is the function of controllers in robots?
In robots, a controller is the device that controls all their actions. It means that a controller helps the robots decide the output according to the input. They perform the tasks according to their programming. The controller processes the input information given by the sensors and helps the robot to take the appropriate action.
What is the use of a battery in robots?
Batteries are a practical and adaptable power source since they can be recharged and changed as needed.
Explain end-effectors with the help of an example.
The end-effectors are attached to the end of the manipulator. Different end effectors are designed to perform different tasks.
For example, to perform the welding task the robot should have welding torch as an end effector. In the same way, to perform a painting task, the robot should have a paint brush as an end effector.
Give names of two industrial and two humanoid robots.
Industrial Robots: ABB IRB 2600 Robot, KUKA KR 60-3 Robot
Humanoid Robots: ASIMO, Atlas
Write any four types of controllers that can be used in robots.
The four types of controllers that can be used in robots are:
Microcontrollers — A microcontroller is a tiny computer embedded on a single chip. It consumes very low power and is used to control the functions of a robot.
Programmable Logic Controllers (PLCs) — PLCs are the programmable controllers that are specifically designed to work in industrial environment. The main purpose of PLCs is automating manufacturing process.
Digital Signal Processors (DSPs) — A DSP controller in robotics processes sensor data to control robotic components with precision, enhancing their responsiveness and accuracy. The DSPs may be used to process image, audio and video data.
Microprocessor — It processes information and helps the robot take decisions and perform tasks.
Explain the various power sources that can be used in robots.
The various power sources that can be used in robots are as follows:
Batteries — Batteries may have different sizes and chemical composition. Due to their tiny size and portable features, these are the most suitable for mobile robots. Batteries are a practical and an adaptable power source since they can be recharged and changed as needed.
Electrical Outlets — This source of power is suitable for the robots that are designed to work in a fixed area or location. This power source is generally used for industrial robots, which are designed for specific location and need high power.
Solar Panels — This source of power is used to provide energy to the robots that are designed to work in outdoor environment. These sources produce electricity through sunlight.
Discuss the working principle of the mechanical block of robots.
The mechanical block of a robot is responsible for creating a robot's physical structure. It also provides a mechanism for movement and interaction of the robot with its environment. To make the robot work properly and in challenging situations, the mechanical components of the robot should be robust and reliable.
Functioning and Working Principle:
The functioning of this block is based on the following aspects:
What are the important components of a humanoid robot ?
Humanoid robots are the robots that look and work like humans. Some important components of humanoid robots are:
Explain the various components of a mobile robot.
The various components of a mobile robot are:
What would happen if robots did not have controllers?
If robots did not have controllers, they would not be able to perform any action.
Without a controller, a robot would not process sensor input, not control actuators, and hence would fail to function properly.
Research on any one humanoid robot and identify its benefits and limitations.
Humanoid Robot: ASIMO
ASIMO is a humanoid robot developed by Honda. It is designed to look and work like a human. ASIMO can walk, run, climb stairs, jump, and interact with people.
Benefits of ASIMO:
Limitations of ASIMO:
How are underwater robots useful for cleaning of oceans? Research and find the answer.
Underwater robots are very useful for the cleaning of oceans as they can work in deep and dangerous underwater environments where humans cannot easily operate.
Press ↓ to reveal a solution and move to the next question. Back to Solutions for Class 9 KIPS ICSE Robotics & Artificial Intelligence.