ICSE Class 9 Robotics & AI · Solutions for Class 9 KIPS ICSE Robotics & Artificial Intelligence · 38 solved questions
Exercise
1Activity 3.1
Identify the type of motion in the following robots.
(a)Straight line movement of a robot. Motion type ...............
(b)Robot spinning around a fixed axis. Motion type ...............
(c)The motion of planets in solar system as they revolve around the sun. Motion type ...............
(d)Turning a steering wheel. Motion type ...............
Show SolutionHide Solution↓
The types of motion in the given robots are:
Linear motion
Angular motion
Circular motion
Angular motion
1Activity 3.2
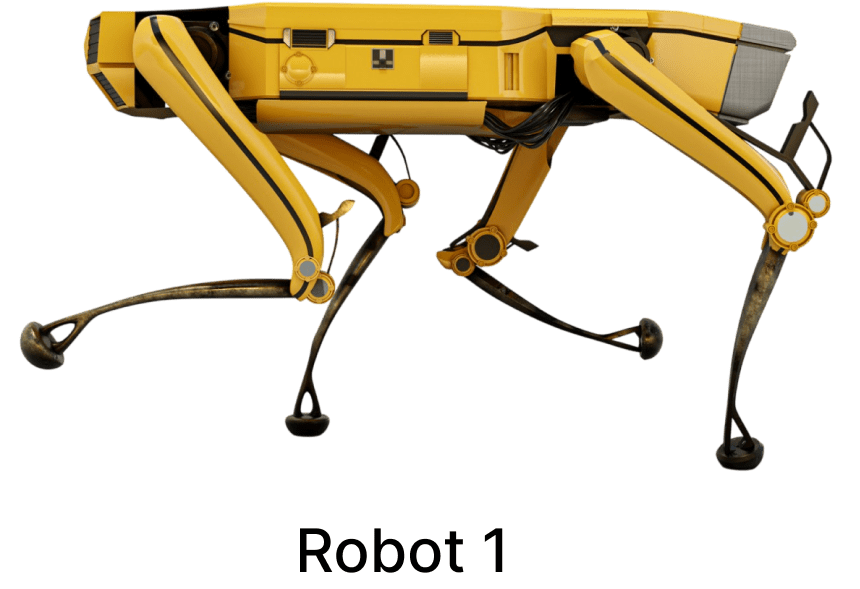
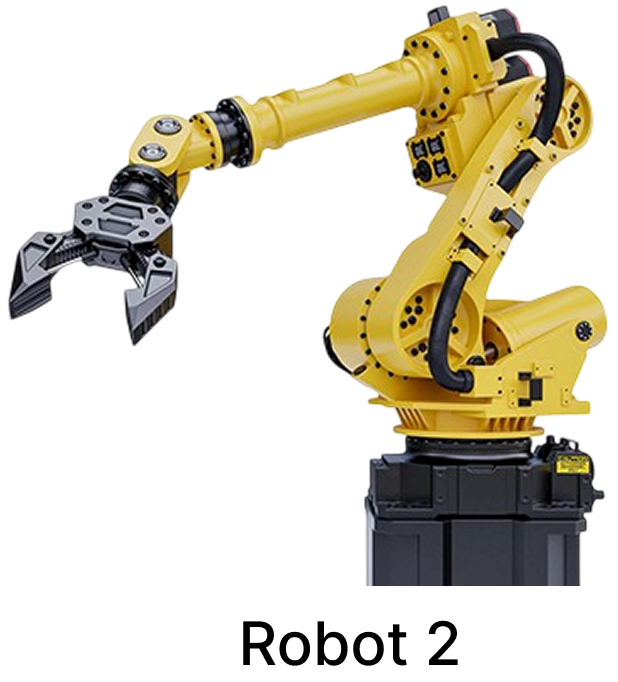
Observe the two robots, identify the types of links and joints they have, and mention the same in the below-given table.
Component
Robot 1
Robot 2
Links
Joints
Show SolutionHide Solution↓
Component
Robot 1
Robot 2
Links
Rigid links
Rigid links
Joints
Revolute joints
Spherical joints
1Activity 3.3
Write the number of joints and links in the given figure.
Show SolutionHide Solution↓
Links: 3
Joints: 2
2Activity 3.3
Name the types of joints in the given figure.
Show SolutionHide Solution↓
The types of joints shown in the given figure are:
1Activity 3.4
What would be the degrees of freedom of the following robotic arm?
Show SolutionHide Solution↓
The given robotic arm has six Degrees of Freedom (6 DoF).
1State True or False
Angular motion can occur in multiple axes simultaneously.
Show SolutionHide Solution↓
False
Reason — The rotating movement of an object or a component of a system around a fixed point or axis is referred to as angular motion. Hence, angular motion takes place about a single fixed axis at a time and is not simultaneous in multiple axes.
2State True or False
Linear motion represents movement along a straight-line path.
Show SolutionHide Solution↓
True
Reason — Linear motion refers to the movement in a straight line along a specific path.
3State True or False
For robots to navigate complicated environments, one-dimensional motion is adequate.
Show SolutionHide Solution↓
False
Reason — One-dimensional movement of a robot may not be sufficient for complex applications that require the robot to move in multiple directions.
4State True or False
Movement in one dimension is restricted to linear movement and cannot include rotation.
Show SolutionHide Solution↓
True
Reason — One-dimensional motion in a robot refers to the movement of the robot along a single axis, such as the X, Y, or Z axis, in a straight line. It involves motion in only one direction, either forward or backward, and does not allow movement in any other direction.
5State True or False
Angular motion is required for tasks including pivoting and joint rotation.
Show SolutionHide Solution↓
True
Reason — The rotating movement of an object or a component of a system around a fixed point or axis is referred to as angular motion. Since pivoting and joint rotation involve rotation about a fixed point or axis, angular motion is required for such tasks.
6State True or False
Greater number of limbs in a mechanical arm will always result in more Degrees of Freedom.
Show SolutionHide Solution↓
True
Reason — Degree of Freedom (DoF) in robots is referred to as the number of free movements a robot can perform. A robot’s DoF is determined by its mechanical design and number of joints. Each joint offers a single degree of freedom. Limbs of a mechanical arm are formed by links and are connected through joints. Therefore, an increase in the number of limbs requires an increase in the number of joints, which in turn increases the Degrees of Freedom.
7State True or False
A robot arm's flexibility and movement range are determined by its Degrees of Freedom.
Show SolutionHide Solution↓
True
Reason — Degree of Freedom (DoF) in robots is referred to as the number of free movements a robot can perform. Since Degrees of Freedom represent the number of independent movements a robot arm can perform, they determine the flexibility and range of movement of the robot arm.
Reason — Prismatic joints are also known as linear joints. These joints allow the links to move in a straight line along an axis. Hence, prismatic joints facilitate straight-line translational motion.
9State True or False
Robot linkages are able to connect joints in a straight path and cannot build complicated configurations.
Show SolutionHide Solution↓
False
Reason — Links and joints determine the shape, size, and mobility of a robot. Since links and joints together form a robot’s mechanical framework and determine its shape and mobility, robot linkages can be arranged to build complex configurations and are not restricted to a straight path.
10State True or False
Circular motion is defined as movement along a curved path.
Show SolutionHide Solution↓
True
Reason — The movement of an object or a particle along a circular path or trajectory is referred to as circular motion.
1Select the correct option
Which type of joint permits rotation in multiple axes?
(a)Revolute joint
(b)Spherical joint
(c)Prismatic joint
(d)None of these
Show SolutionHide Solution↓
Spherical joint
Reason — Spherical joints, also known as ball and socket joints, provide the most freedom of movement among all joint types. They allow the links to rotate around multiple axes, enabling the robot to move in multiple directions.
2Select the correct option
Which type of joint permits single axis rotation?
(a)Prismatic joint
(b)Spherical joint
(c)Revolute joint
(d)None of these
Show SolutionHide Solution↓
Revolute joint
Reason — Revolute joints, also known as rotary joints, allow the links to rotate around an axis.
3Select the correct option
What kind of robot movement takes a curved path?
(a)Linear motion
(b)Circular motion
(c)Angular motion
(d)None of these
Show SolutionHide Solution↓
Circular motion
Reason — The movement of an object or a particle along a circular path or trajectory is referred to as circular motion.
4Select the correct option
What kind of robot movement revolves around a fixed point?
(a)Linear motion
(b)Circular motion
(c)Angular motion
(d)None of these
Show SolutionHide Solution↓
Angular motion
Reason — The rotating movement of an object or a component of a system around a fixed point or axis is referred to as angular motion.
5Select the correct option
What kind of robot movement involves the straight line back and forth movement?
(a)Linear motion
(b)Angular motion
(c)Circular motion
(d)None of these
Show SolutionHide Solution↓
Linear motion
Reason — Linear motion refers to the movement of a robot in a straight line along a specific path. Since back and forth movement takes place along the same straight line, the motion involved is linear motion.
6Select the correct option
How many Degrees of Freedom (DoF) are there in a robot arm with a single revolute joint?
(a)One
(b)Two
(c)Three
(d)Four
Show SolutionHide Solution↓
One
Reason — Each joint offers a single degree of freedom. Since the robot arm has one revolute joint, it has one Degree of Freedom.
7Select the correct option
How many Degrees of Freedom does a robot arm with one prismatic joint and one revolute joint normally have?
(a)One
(b)Two
(c)Three
(d)Four
Show SolutionHide Solution↓
Two
Reason — Each joint offers a single degree of freedom. Since the robot arm has one prismatic joint and one revolute joint, it has two joints, and therefore two Degrees of Freedom.
8Select the correct option
How many DoF are there in a robot arm having three revolute joints?
(a)Two
(b)Three
(c)Four
(d)One
Show SolutionHide Solution↓
Three
Reason — Each joint offers a single degree of freedom. Since the robot arm has three revolute joints, and each joint provides one Degree of Freedom, the total Degrees of Freedom are three.
9Select the correct option
A robot arm raising something vertically is a prime example of:
(a)One-dimensional motion
(b)Two-dimensional motion
(c)Three-dimensional motion
(d)All of these
Show SolutionHide Solution↓
One-dimensional motion
Reason — One-dimensional motion in a robot refers to the movement of the robot along a single axis, such as the X, Y, or Z axis, in a straight line. Raising an object vertically involves movement along only the Z-axis in a straight line, which is an example of one-dimensional motion.
10Select the correct option
Which of the following describes a robot's movement in two dimensions?
(a)Extending a robotic arm
(b)Rotation around a fixed axis
(c)Straight line movement
(d)Moving in a circle
Show SolutionHide Solution↓
Moving in a circle
Reason — Two-dimensional motion in robots refers to the ability of a robot to move and navigate on a two-dimensional plane along the X and Y axes. Movement in a circle takes place on a plane and involves motion along more than one direction, therefore it represents two-dimensional motion.
1Fill blanks
Fill in the blanks:
(a)A robotic arm's ............... affects the range of independent movements it can do.
(b)Revolute joints in a robotic arm permit ............... motion.
(c)The rotating movement of an object or a component of a system around a ............... is referred to as angular motion.
(d)Prismatic joints in a robotic arm permit ............... motion.
(e)............... Degrees of Freedom are provided by a robotic arm having two revolute joints.
Show SolutionHide Solution↓
A robotic arm's Degree of Freedom affects the range of independent movements it can do.
Revolute joints in a robotic arm permit Rotational or Angular motion.
The rotating movement of an object or a component of a system around a Point or Axis is referred to as angular motion.
Prismatic joints in a robotic arm permit Translational or Linear motion.
Two Degrees of Freedom are provided by a robotic arm having two revolute joints.
1Short answer type questions
What is the purpose of robot arm links in the overall structure of a robot? Explain.
Show SolutionHide Solution↓
A link is a rigid or flexible element that connects two or more joints. Links, together with joints, determine the shape, size, and mobility of a robot. They provide structural support and enable the robot arm to perform movements and carry out tasks effectively.
2Short answer type questions
What is the role of revolute joints in a robot arm? Explain with an example.
Show SolutionHide Solution↓
Revolute joints, also known as rotary joints, allow the links to rotate around an axis. These joints enable the robot arm to move its parts in different directions by providing angular motion. Example: Revolute joints are commonly found in robotic arms and legs as they allow a robot to move its joints in different directions.
3Short answer type questions
Explain the relationship between the number of joints and the degrees of freedom in a robot arm.
Show SolutionHide Solution↓
Degree of Freedom (DoF) in robots is referred to as the number of free movements a robot can perform. A robot’s DoF is determined by its mechanical design and the number of joints. Each joint offers a single degree of freedom, enabling the robot to move or rotate along a particular axis. A robotic arm's degrees of freedom can be increased by integrating multiple joints.
4Short answer type questions
How can the degrees of freedom in a robot arm affect its flexibility and range of motion?
Show SolutionHide Solution↓
A robot arm with more Degrees of Freedom can perform more independent movements, allowing it to reach different positions and orientations. Therefore, an increase in the Degrees of Freedom enhances the flexibility of the robot arm and expands its range of motion, enabling it to perform more complex tasks effectively.
5Short answer type questions
Explain the term 'coordinated joint movement'.
Show SolutionHide Solution↓
Coordinated joint movement refers to the simultaneous and controlled movement of multiple joints in a robot to produce a desired motion.
Linear motion: Coordinated joint control is required to produce linear motion at prismatic joints. The connected links travel in a straight path by concurrently manipulating the expansion or retraction of the joints. The speed and direction of linear motion are determined by the velocity and direction of the joint movement.
Circular motion: Coordination of the revolute joints is required to provide circular motion. The links move in a fashion that follows a circle by concurrently managing the rotation of the joints. The joint's rotation speed and direction determine the circular motion's speed and direction.
Angular motion: In angular motion, the connected links move around their respective axes by concurrently controlling the rotation of the joints. The joints’ rotation speed and direction define the speed and direction of angular motion.
1Long answer type questions
Explain two-dimensional motion in robots with the help of an example.
Show SolutionHide Solution↓
The ability of a robot to move and navigate on a two-dimensional plane is referred to as two-dimensional motion in robots. It employs both linear and rotational mobility along the X and Y axes, allowing the robot to move, turn, and interact within a two-dimensional workspace. Within this plane, the robot is capable of moving forward, backward, left, right, and diagonally.
Example:
Mobile robots: Wheeled or tracked robots can move in a two-dimensional plane by directing their linear motion along the X and Y axes. They may go in any direction within the plane by modifying the speeds and directions of their wheels or tracks.
2Long answer type questions
What are the important characteristics of angular motion?
Show SolutionHide Solution↓
The important characteristics of angular motion are as follows:
The object rotates in a plane perpendicular to the axis of rotation.
Angular displacement is the change in the angular position of an object or a component of a system. It represents the angle through which the object has rotated and is usually measured in degrees or radians.
Angular velocity describes the rate at which an object or a component of a system rotates. It is defined as the rate at which angular displacement changes per unit of time.
Angular acceleration is the rate at which an object's angular velocity varies. It is defined as the rate at which angular velocity changes per unit of time.
3Long answer type questions
Write and explain various types of joints in robots.
Show SolutionHide Solution↓
The various types of joints in robots are explained as follows:
Prismatic Joints: Prismatic joints are also known as linear joints. These joints allow the links to move in a straight line along an axis. A common example of a prismatic joint is the sliding mechanism in a drawer.
Revolute Joints: Revolute joints, also known as rotary joints, allow the links to rotate around an axis. These joints are commonly found in robotic arms and legs as they allow a robot to move its joints in different directions.
Spherical Joints: Spherical joints, also known as ball and socket joints, provide the most freedom of movement among all joint types. They allow the links to rotate around multiple axes, enabling the robot to move in multiple directions. Spherical joints are commonly found in the human shoulder and hip joints.
4Long answer type questions
Make a diagram of a robotic arm with seven Degrees of Freedom and explain it.
Show SolutionHide Solution↓
A robotic arm with six revolute joints and one prismatic joint can accomplish seven degrees of freedom in total. The six revolute joints provide six degrees of freedom, while the prismatic joint adds one more. The given picture shows a robotic arm with seven DoF.
1Higher Order Thinking Skills (HOTS)
Find out any five activities in your surroundings or daily routine that use prismatic joints. Discuss their functioning in detail.
Show SolutionHide Solution↓
A prismatic joint is a type of joint that allows linear (straight-line) translational motion along a fixed axis. The following activities use prismatic joints:
Opening and closing a drawer: A drawer moves back and forth in a straight line along fixed rails. This sliding movement is an example of a prismatic joint, where motion is restricted to one direction only.
Scissors lift or fork lift: A scissors lift moves only upward and downward. The platform rises and lowers through a sliding mechanism, which represents linear motion produced by a prismatic joint.
Robotic slider (camera slider): A robotic slider moves a platform or camera along a straight rail. The carriage slides forward or backward, showing the use of a prismatic joint to produce linear motion.
Height adjustment of an office chair: When adjusting the height of an office chair, the central column slides vertically. This up-and-down movement along a single axis is an application of a prismatic joint.
Sliding door mechanism: A sliding door moves horizontally along a fixed track. The door does not rotate but translates in a straight line, which matches the functioning of a prismatic joint.
2Higher Order Thinking Skills (HOTS)
What effect does the number of joints in a robot arm have on its total reach and manoeuvrability? Discuss various examples.
Show SolutionHide Solution↓
The number of joints in a robot arm has a significant effect on its total reach and manoeuvrability. Each joint allows the robot arm to move or rotate in a particular direction. Therefore, an increase in the number of joints increases the Degrees of Freedom, which improves the robot arm’s ability to move flexibly and reach different positions.
Effect on Reach: A robot arm with more joints can extend, bend, and adjust its position more effectively. This enables the arm to reach objects located at different distances and orientations, including positions that are difficult to access with fewer joints.
Effect on Manoeuvrability: Manoeuvrability refers to how easily a robot arm can change direction and orientation. With more joints, the arm can perform coordinated and complex movements, allowing smoother motion and better control while performing tasks.
Examples:
Three Degrees of Freedom robotic arm A robot arm with three joints can perform basic movements such as lifting and placing objects. Its reach and manoeuvrability are limited, making it suitable for simple tasks.
Four Degrees of Freedom robotic arm A robot arm with four joints has improved stability and flexibility. It can be used for tasks such as stacking boxes, loading machines, and pick-and-place operations.
Seven Degrees of Freedom robotic arm A robot arm with seven joints has high reach and manoeuvrability. It can move in multiple directions, follow complex paths, and perform precise and human-like movements.
3Higher Order Thinking Skills (HOTS)
Find out any five activities in your surroundings or daily routine that use revolute joints. Discuss their functioning in detail.
Show SolutionHide Solution↓
A revolute joint is a type of joint that allows rotational movement around a fixed axis. In such joints, one part rotates relative to another, similar to the motion of a hinge. The following activities from daily life use revolute joints:
Opening and closing a door A door rotates about its hinges fixed to the door frame. The hinge acts as a revolute joint, allowing the door to rotate in one direction around a fixed axis.
Turning a steering wheel of a vehicle The steering wheel rotates around a central axis. This rotational movement helps control the direction of the vehicle and is an example of a revolute joint.
Movement of the elbow joint in the human arm The elbow allows the forearm to rotate around a fixed point relative to the upper arm. This hinge-like movement is similar to a revolute joint and enables bending and straightening of the arm.
Pedals of a bicycle Bicycle pedals rotate about their central axle. This rotational motion helps convert the rider’s force into movement, demonstrating the working of a revolute joint.
Rotation of a ceiling fan The blades of a ceiling fan rotate around a fixed central axis. This continuous rotational motion is an example of a revolute joint in operation.
We use essential cookies for sign-in and cookieless traffic measurement. Optional analytics help us improve the question bank; nothing optional loads until you allow it.