The process of building a simple wheeled mobile robot involves the following steps:
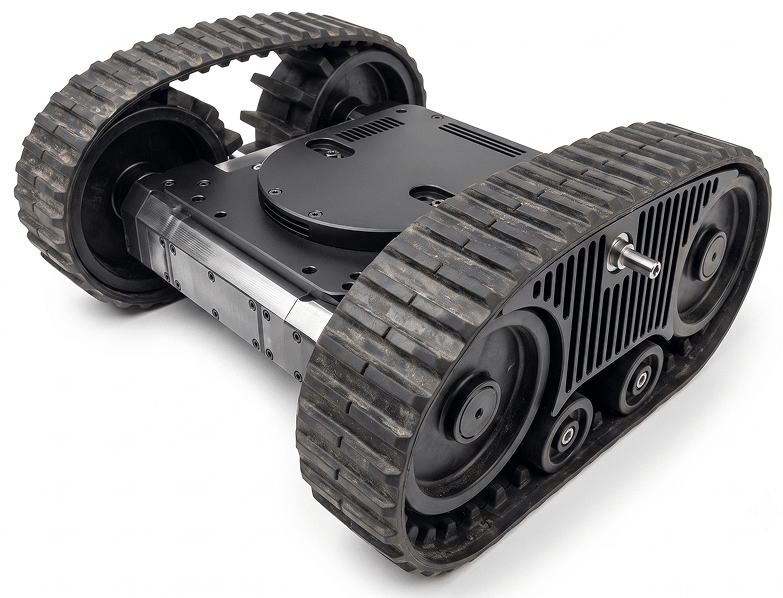
Step 1: Design the Chassis
Select or build a frame to support all components using materials like acrylic, aluminium or plastic.
Step 2: Attach Wheels
Choose appropriate wheels for the terrain and use two or four wheels depending on the design.
Step 3: Install Motors
Attach DC motors or stepper motors to the wheels for movement and ensure proper connection to the chassis.
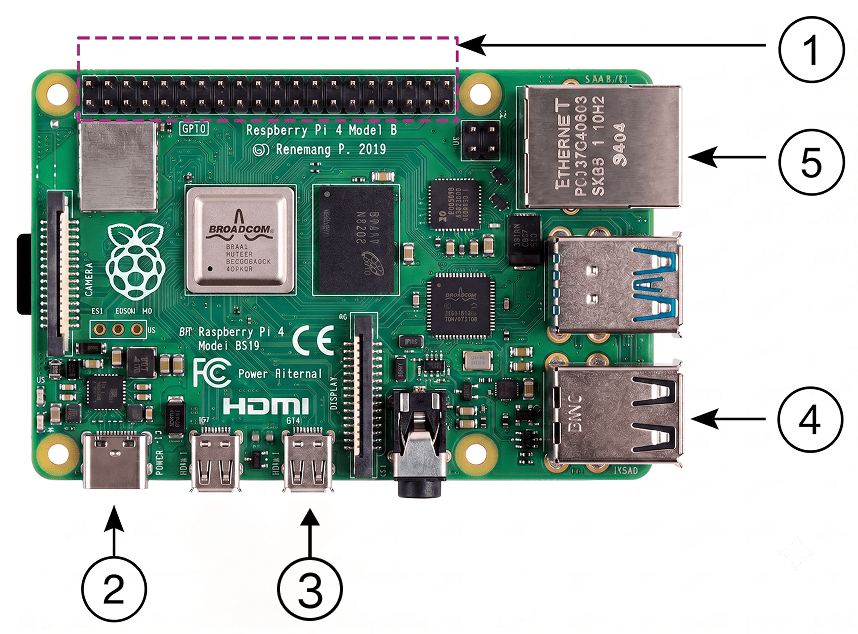
Step 4: Add a Microcontroller
Use a controller like Arduino or Raspberry Pi to manage the operations of the robot.
Step 5: Integrate Sensors
Add sensors such as ultrasonic or infra-red modules for navigation and obstacle detection.
Step 6: Connect Power Supply
Use batteries to power the motors and electronics, ensuring proper voltage regulation.
Step 7: Write the Program
Develop and upload the code to the microcontroller to control the robot’s movement and behaviour.
Step 8: Test and Adjust
Test the functionality of the robot and make necessary adjustments.